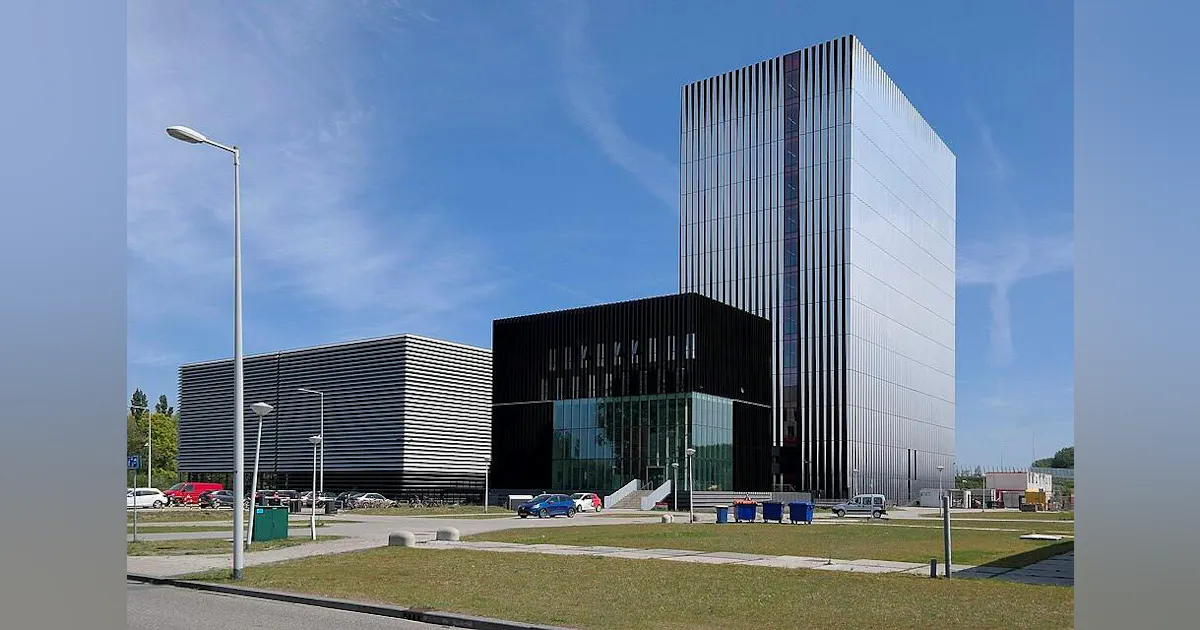
As governments pursue competing approaches to AI regulation and infrastructure development, data center operators face growing pressure to document security controls, verify workload...
/PRNewswire/ -- Asuri today announced the launch of its multi-agent enterprise AI platform, designed to help businesses move beyond copilots and deploy...
MOUNTAIN VIEW, Ca., October 21, 2026--Bloomreach, the AI company for personalized customer engagement, today announced that brands, technology partners, and agencies around the world have already built more than 200 agents using Loomi Connect, the integration foundation for its Loomi intelligence layer. Loomi comprises multiple models, including purpose-built, adaptive models that learn from each business’s unique data, orchestrated together to drive revenue. Loomi Connect gives businesses a str
Optical chiplets for AI data centers gained Japan government backing as NEDO selected an NTT-led consortium to develop silicon photonics mass-production infrastructure. The project targets production samples in 2028 and requires a tenfold manufacturing productivity gain to become commercially
DeepSeek-V4.1-Flash-1017 is a minor update to DeepSeek-V4.1-Flash, delivering substantial improvements across reasoning, coding, agentic tasks, and visual benchmarks. Alongside these gains, the model reduces task execution time and output length, enabling users to complete…
Multilingual code language models transfer skills across programming languages (PLs), but whether any PL occupies a privileged pivot position remains contested: geometric analyses point to C-family languages and Go, while behavioral evidence highlights Python. We revisit this…
Automated operations research (OR) modeling requires LLMs to translate natural-language decision problems into correct mathematical programs. Existing methods can improve individual formulations, but they often solve problems in isolation, retaining little reusable experience…
Physics-informed neural networks (PINNs) use one shared representation over the computational domain, which can become difficult to optimize on long domains and for high-order operators. We study a minimal alternative: multiply the first hidden activation of an otherwise…
Robotic grasping is typically formulated as the problem of identifying successful actions from a space of candidate grasp poses. However, the organization of successful actions within this space has received less attention. We study the multiscale structure of viable robotic…