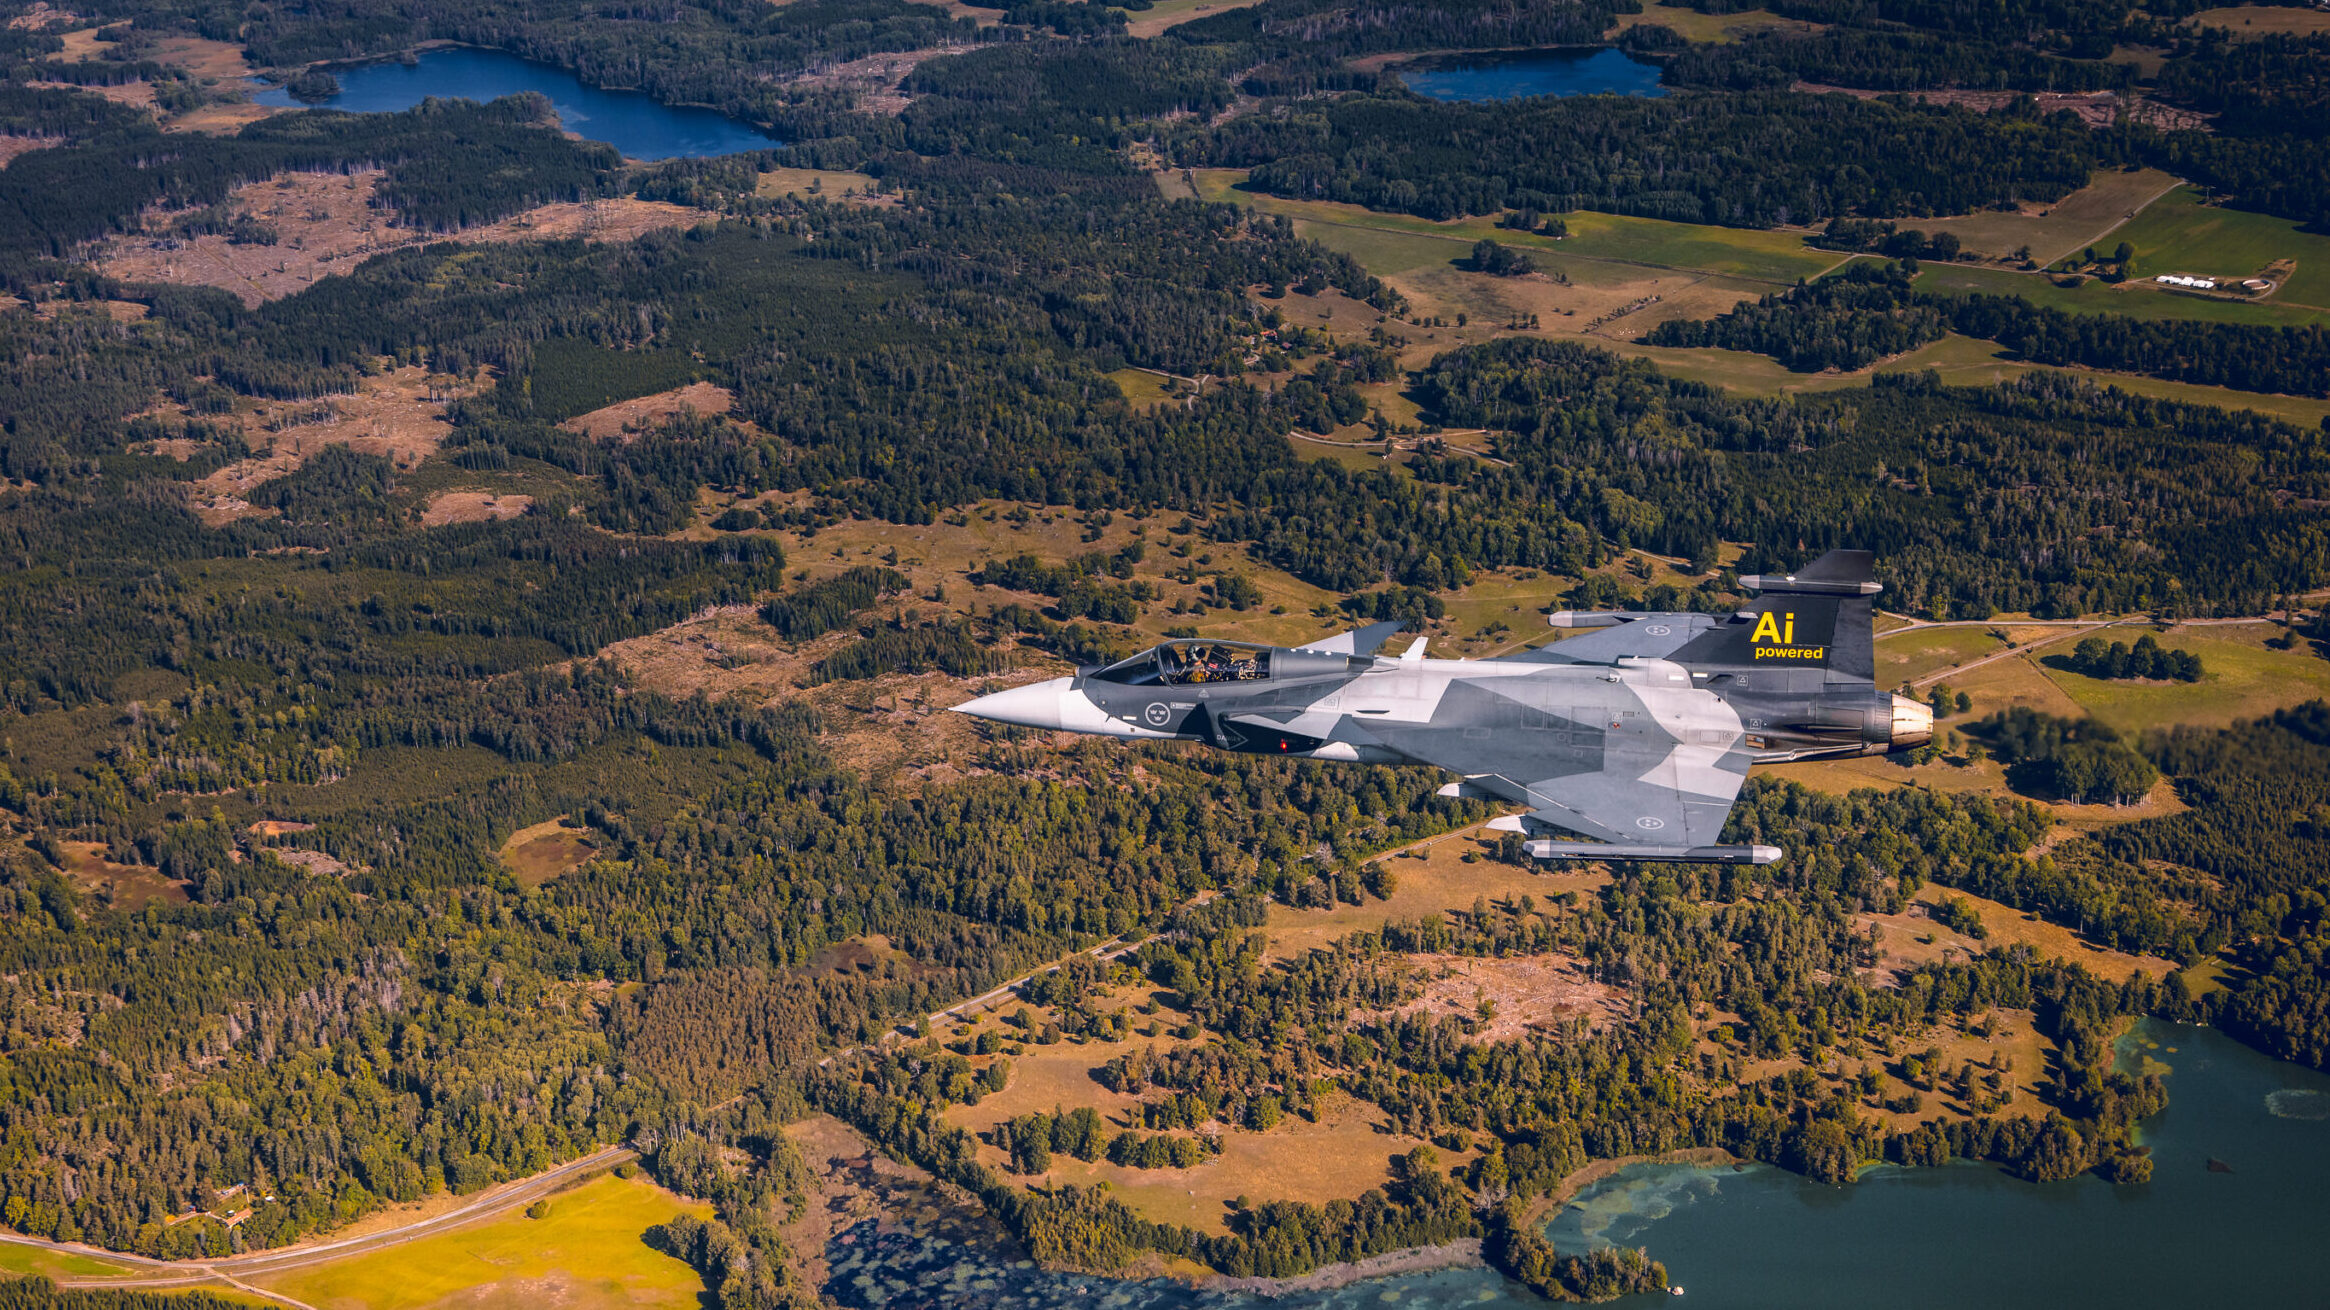
Key to the autonomous project is Saab’s AI Fighter Jet Pilot Academy, designed to develop the agents and, in parallel, establish infrastructure necessary to “create, train and evaluate” them, says the firm.
AI is evolving at a rapid pace, and the uptake of Generative AI (GenAI) is revolutionising the way humans interact and leverage this technology. GenAI is
General-purpose mobile manipulation requires a combination of capable robot hardware, scalable demonstration collection, expressive whole-body control, and effective policy learning. Yet these components are often developed independently, creating mismatches that limit the capabilities of the complete system. We present Pixel, a co-designed full-stack system for learning general-purpose mobile manipulation. Pixel combines a low-cost wheeled humanoid with human-aligned kinematics and compliant grippers, multiple teleoperation and robot-free human data-collection interfaces, a unified whole-body controller, and a common policy learning pipeline across human and robot demonstrations. A hierarchical learning stack further enables language-conditioned visuomotor control and long-horizon task execution. We evaluate the system across hardware, data collection, and policy learning, and demonstrate mobile-manipulation behaviors requiring dexterity, active perception, navigation, and whole-body coordination. We hope that Pixel provides an integrated and extensible foundation for studying how robot hardware, data, control, and learning can be designed together for robot learning. More…
Idol turns one picture of an object into a 3D Gaussian splat. Give it a render, a generated image or a photo: it removes the background, frames the object and generates up to 1,048,576 Gaussians, written as a standard 3DGS .ply. It runs on consumer GPUs, using 7.2 GB of VRAM…
Editor’s note: This article is republished from Jumpstart, a TechNode Group publication. The brands competing to clean the world’s floors have something less visible in common. According to Amicro, eight of the world’s ten leading smart cleaning robot companies have used its…
A/B testing requires large sample sizes, long timelines, and significant costs. When auxiliary predictions of experimental outcomes are available from machine learning models, uncertain prediction quality precludes replacing human experiments entirely, yet these predictions may…
Multi-organ segmentation using deep learning requires large amounts of annotated patient data; however, institutions often lack sufficiently large and diverse annotated datasets. Privacy constraints further prevent institutions from sharing patient data to overcome this…
Latent world models learn predictive representations for autonomous driving, but the relational semantics these states preserve often remain implicit. We investigate whether traffic scene graphs can serve as privileged semantic supervision for latent world representations.…
How should natural language processing models be selected and adapted for global health literature in environments where annotated data and computational resources are limited? This thesis investigates these challenges through experiments on semantic tag discovery, named entity…